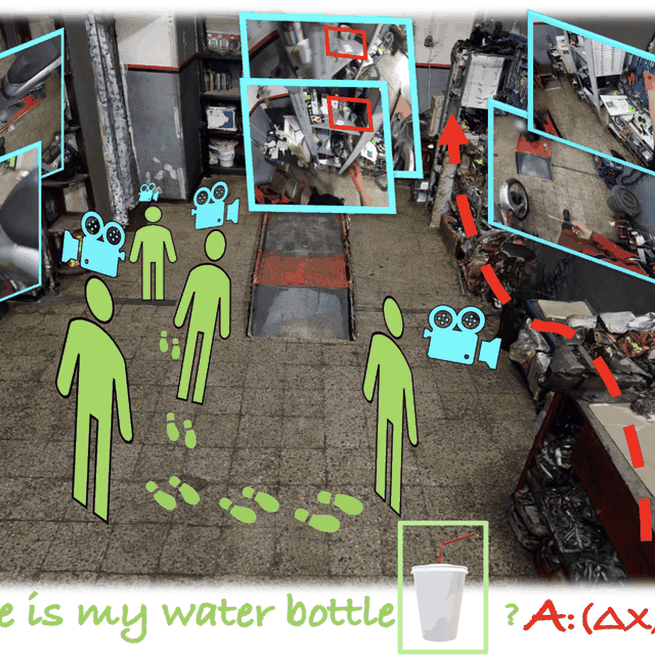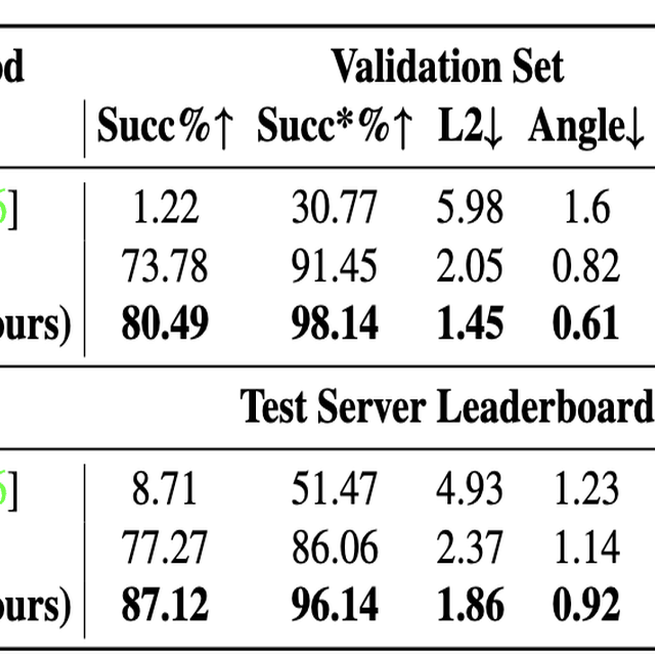
EgoLoc: Revisiting 3D Object Localization from Egocentric Videos with Visual Queries
We propose EgoLoc, a novel approach for localizing 3D objects from egocentric videos, achieving SOTA performance on the Ego4D VQ3D task with 87.12% success rate over previous SOTA of only 8%.
Oct 1, 2023
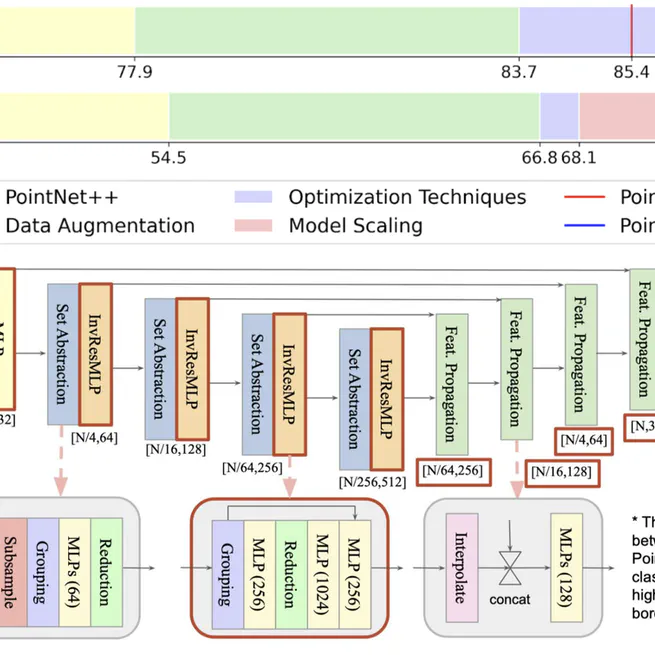
PointNeXt: Revisiting PointNet++ with Improved Training and Scaling Strategies
We revisit PointNet++ and propose PointNeXt, a next-generation PointNet architecture.
Nov 1, 2022
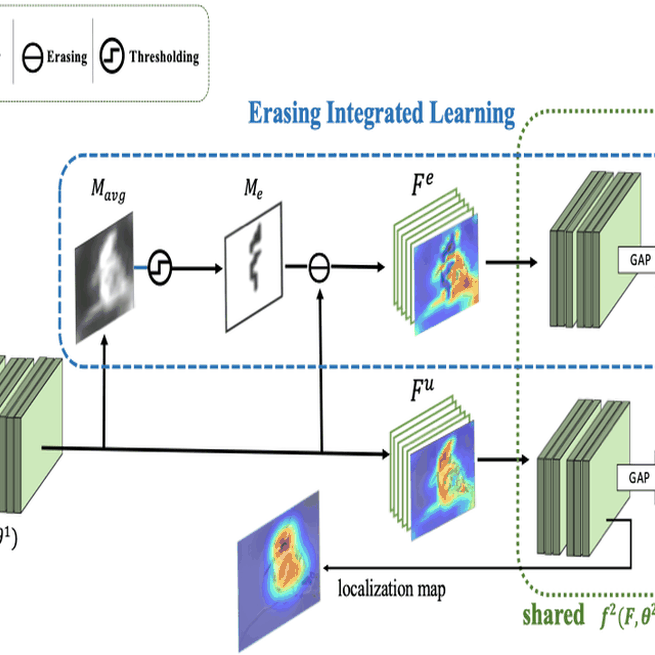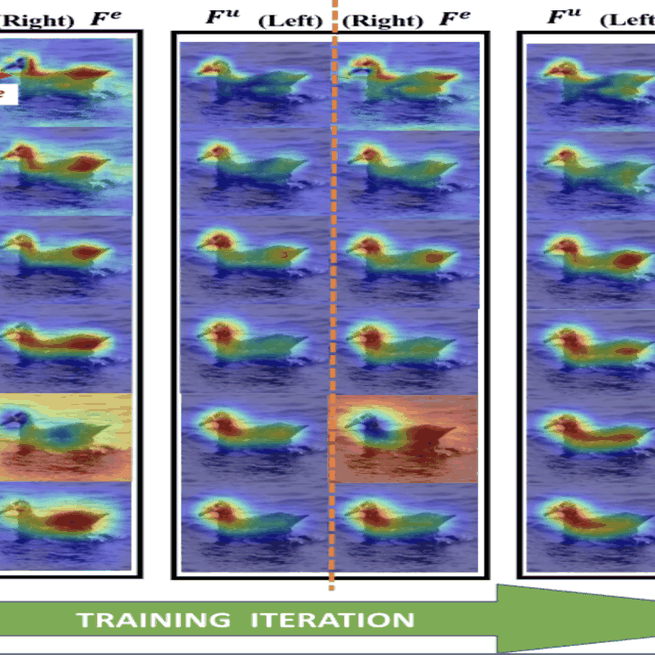
Erasing Integrated Learning : A Simple yet Effective Approach for Weakly Supervised Object Localization
We propose EIL, a novel adversarial erasing technique for weakly supervised object localization.
Oct 1, 2020